
Lecture
Kolmogorov's differential equations (KDE) serve to describe the variability of the state probabilities of a multi-element system subject to failures and restorations.
It is assumed here that the system operates in continuous time, and its elements change state under discrete flows of failures and restorations with intensities k and µk, respectively; here k = 1,…, m , where m – the number of elements in the system. Under the simplest flow of these events, i.e., given ordinariness of the flow and absence of aftereffect, a Markov process of the system's transitions from state to state arises. The KDE describe such processes.
The variables in the KDE are the state probabilities of the system under study (t), . Obtaining these probabilities as a result of solving the KDE makes it possible to estimate practically important reliability indicators, for example, the probability of failure-free operation of the system.
There are certain rules for forming the KDE. It is convenient to first represent the multi-element system as a state graph. For this purpose, its vertices (states with their probabilities) and arcs (edges) are indicated, labeled k or µk, reflecting the transitions from state to state under the action of the flows of failures or restorations of the system's elements.
Each i-th equation in the KDE is written as follows:
The system of KDE formed in this way has the following vector-matrix form:

where A – (n × n)-matrix of coefficients; P – (n × 1)-vector of probabilities Pi of the states of the system under study; P0 – vector of initial conditions.
A distinctive feature of the KDE (1) is the singularity of matrix A, so an attempt to integrate the system of equations (1) without prior transformation is doomed to failure.
The singularity of A is determined by the presence of a linear relationship among the elements of vector P, expressed by the obvious equality:
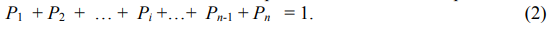
It follows from (2) that the sum of all the equations in the system (1) yields zero, which is possible only under the condition (vector P being generally nonzero) that the sum of the rows of matrix A is a zero row. This statement indicates a linear dependence among the rows of matrix A and explains the reason for its singularity. If desired, this statement can be used as a criterion for the correctness of the formation of matrix A.
It is easy to verify that the eigenvalues (e.v.) of matrix A are real, and (n – 1) of these e.v. are negative, while one e.v. is zero. It follows that the problem of determining vector P can be solved by reducing the number of equations (1) by one, using (2). From (2) any one variable can be expressed in terms of the others.
Let us perform this transformation by eliminating the last element of vector P from (1):
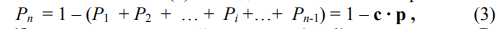
where p – the [(n – 1) × 1]-vector composed of the first (n - 1) members of vector P; c – the [1 × (n – 1)]-row consisting of ones:

After the transformations we obtain the (n – 1) first equations of system (1) in the form:

where R – the [(n – 1) × (n – 1)]-upper diagonal block of matrix A; b – the [(n – 1) × 1]-vector composed of the first (n - 1) members of the n-th (last) column of matrix A. Matrix M – the nonsingular kernel of matrix A, so the indicator of the correctness of the transformations is the coincidence of the e.v. of matrix M with the nonzero e.v. of matrix A.
Equations (5) can now be used in solving applied problems of analyzing reliability characteristics both in dynamics and in statics (as t → ∞). In any case, the first (n - 1) elements of vector P are determined from equations (5); the last element Pn, previously excluded from the KDE, is found from expression (3). Analysis of the dynamics of the change in the state probabilities is carried out by integrating equations (5). The steady-state value of these probabilities is found from the following relation:

When solving applied problems of analyzing multi-element systems with failures and restorations using the KDE, so-called direct and inverse problems can be solved. The direct problem involves the analysis of state probabilities and reliability characteristics for given specific values of the intensities.
The solution of the inverse problem involves finding the failure and/or restoration intensities using one of the possible criteria, for example, maximizing the probability of failure-free operation.

Comments